Subtotal:
$0.00
Robotic Parking: The Complete Guide to Parking Robots, Automated Valet Parking and AutoMoverBot Part Two
17. Robotic Parking for Offices and Commercial Buildings
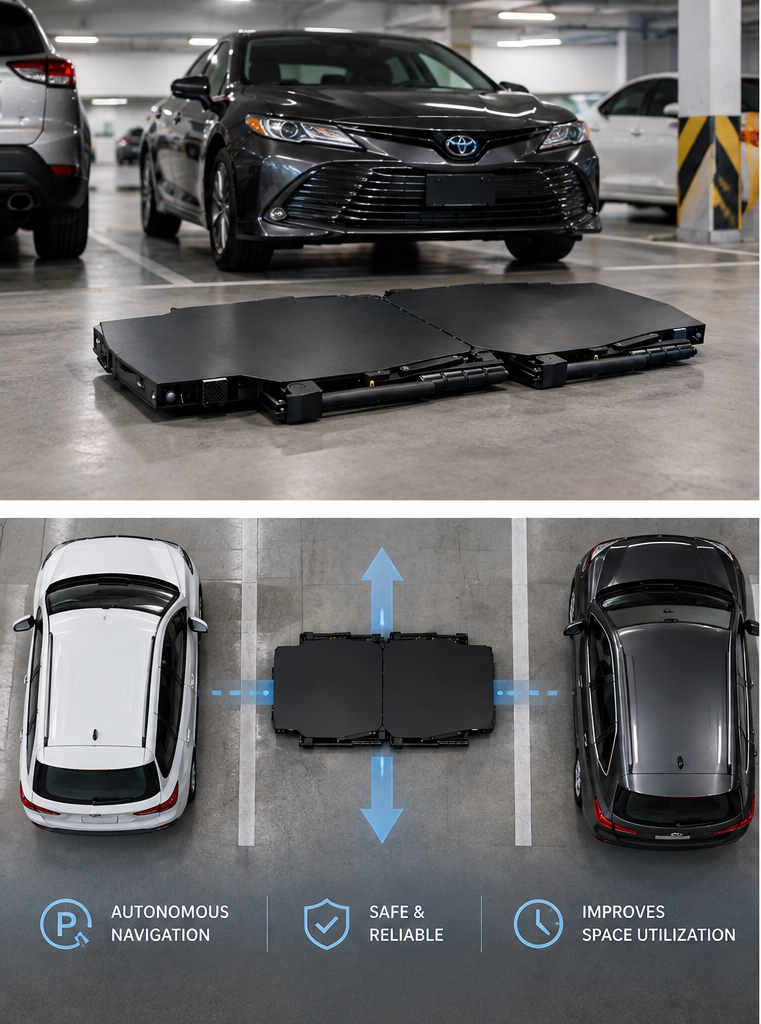
Office car parks typically have sharp arrival and departure peaks. A system that appears efficient during a quiet hour can frustrate users if it does not cope at 08:30 and 17:30. Queue capacity, tenant communication, release authority, delivery-lane geometry and manual fallback all shape the actual service.For a private, controlled garage, an AMR may be assessed when vehicle classes and routes are known. A new-build seeking structural density may assess mechanical APS. An AVP concept needs compatible vehicles and prepared infrastructure. The decision should be architecture-led, not driven by the generic phrase “smart parking”.
18. Robotic Parking for Manufacturing and Vehicle Plants
Manufacturing sites may have repeatable movements among end-of-line, quality, rework, storage, charging and dispatch. The controlled environment and trained workforce can make an AMR pilot more tractable than public parking. The constraints are also stringent: production systems, quality holds, route changes, mixed traffic and takt-time effects require formal interface and safety management.
| Plant task | Potential value | Evidence needed before scale-up |
| Finished-vehicle staging | Repeatable movement and recordability. | Cycle-time, buffer and peak-flow study. |
| Quality-control placement | Controlled positioning for inspection. | Clearance, floor and inspection-access test. |
| Rework/service | Approved move of restricted vehicles. | Vehicle-specific handling and quarantine procedure. |
| Yard logistics | Organised locations for outbound/inbound stock. | Outdoor environment and resilience qualification. |
| Production support | Reduced internal driving for selected tasks. | Interlocks, safety integration and downtime plan. |
AutoMoverBot names manufacturing and production lines but does not publish a named plant integration, MES/WMS interface or auditable performance case in the reviewed pages.
19. Robotic Parking for Airports, Rail Stations and Transport Hubs
Transport hubs share valuable land and demand volatility, but airport long-stay demand is not the same as a station’s commuter surge. Park-and-ride sites can experience simultaneous evening retrieval. Mobility hubs may add car clubs, taxis, EV charging and data-sharing. A solution needs a demand model for the actual hub.
| Hub | Demand pattern | Likely focus | Non-negotiable check |
| Airport | Multi-day dwell and flight-bank peaks. | Long-stay storage, valet, rental staging. | Security, weather and retrieval resilience. |
| Rail/high-speed station | Concentrated commuter peaks. | Controlled staff/commuter storage. | Queue and pedestrian management. |
| Park-and-ride | Daily mass arrival/departure. | Purpose-built APS or bounded robot zones. | Very high throughput and robust fallback. |
| Mobility hub | Multiple vehicle/user types. | Reservation-integrated controlled parking. | Data and access-governance clarity. |
| Depot | Fleet-only restricted access. | Vehicle logistics/staging. | Compatibility, charging and shift cover. |
Hong Kong International Airport describes operating automated car-park services with more than 2,800 spaces, using designated cabins and automated transport. The operator page does not identify the equipment vendor or mechanism, so it should not be classified beyond that evidence.
20. The Business Case for Robotic Parking
The business case starts with a measured baseline. Count actual vehicle moves by hour and task. Time the manual process from request to hand-over, including walking, key handling, staging, inspection and exceptions. Record labour cost, space value, revenue, incident history, energy, maintenance, insurance and peak delays. Then model the robot-assisted service, including the operator, technician and IT/OT work it adds.Annual net benefit=avoided or redeployed labour value+realised capacity contribution+other evidenced benefit−annual operating cost\text{Annual net benefit}=\text{avoided or redeployed labour value}+\text{realised capacity contribution}+\text{other evidenced benefit}-\text{annual operating cost}Annual net benefit=avoided or redeployed labour value+realised capacity contribution+other evidenced benefit−annual operating costSimple ROI=annual net benefittotal initial investment×100%andSimple payback=total initial investmentannual net benefit\text{Simple ROI}=\frac{\text{annual net benefit}}{\text{total initial investment}}\times100\%\qquad\text{and}\qquad\text{Simple payback}=\frac{\text{total initial investment}}{\text{annual net benefit}}Simple ROI=total initial investmentannual net benefit×100%andSimple payback=annual net benefittotal initial investmentThese equations organise a decision. They do not create a positive result. Labour should only be counted where hours are genuinely removed or redeployed. Extra capacity should only be counted if demand and permissions make it monetisable. Downtime must include manual recovery and customer consequences where material.
| Variable | Measurement method | Frequent error |
| Daily vehicle moves | Count by task and time period. | Using annual average and ignoring peak demand. |
| Manual/robot-assisted effort | Time study including hand-over and exceptions. | Treating travel speed as total cycle time. |
| Labour cost | Fully burdened finance-approved rate. | Comparing with base wage only. |
| Capacity value | Evidence of usable/sellable new capacity. | Counting theoretical spaces with no demand. |
| Utilisation | Loaded and empty missions versus available time. | Assuming continuous maximum operation. |
| Capex/lease | Quote plus freight, tax, installation and finance. | Comparing a robot line item with complete baseline. |
| Maintenance/support | Contract plus internal time/spares. | Treating it as zero. |
| Energy | Metered or engineered charger/robot use. | Ignoring electrical and resilience cost. |
| Downtime | Probability, duration and manual workaround. | Assuming no consequence of failure. |
| Insurance/security | Actual insurer/finance evidence. | Claiming automatic premium reductions. |
Use conservative, base and upside cases. The conservative case assumes lower utilisation and no speculative capacity revenue. The base case should use pilot evidence. The upside case is sensitivity analysis, not the sole investment justification.
21. How Much Does Robotic Parking Cost?
There is no single robotic-parking price. A single vehicle-moving AMR, a purpose-built multi-level automated garage and an AVP facility upgrade differ in capital scope. Site works, drainage, floor repair, structural review, charging, networking, safety systems, integration, training, support and downtime resilience can matter as much as the machine.AutoMoverBot’s official pages advertise purchase, short-term hire, monthly rental and long-term lease. The reviewed material contains no stable model-specific price or rental tariff. A buy-versus-rent page mentions an approximate US$45,000 indication, but it is not a clearly current, fully scoped quotation; it should not be used as an AutoMoverBot price in an investment model.
| Cost category | Potential contents | Quotation question |
| Robot/fleet | Machine, options, transport, import, commissioning. | Which model/revision and accessories are included? |
| Site works | Floor, drainage, barriers, markings, structure. | Which survey/remediation items are excluded? |
| Charging | Chargers, supply, protection, cable management, fire measures. | What electrical/facility scope is required? |
| Control/software | Licences, hosting, updates, dashboards, support. | What is included initially and recurring? |
| Connectivity/cyber | Radio survey, access points, segmentation and monitoring. | Which network/security requirements are supplier obligations? |
| Integration | Stock, parking, access, CCTV, payment or WMS interfaces. | Are APIs documented and supported? |
| Safety/compliance | Risk assessment, guarding, signs, approvals, fire review. | Who owns each deliverable and residual risk? |
| Training | Operators, supervisors, maintenance and emergency staff. | What refreshers and competence evidence are included? |
| Maintenance/resilience | Visits, parts, battery, spare machine, manual fallback. | What service level, exclusions and response time apply? |
CNBC reported a vendor-attributed US$20,000–US$80,000 per-space range for a particular Miami high-rise in 2024. It is a dated, case-specific building-system statement—not an AMR price, an AutoMoverBot quote or a general market rate.
22. AutoMoverBot Purchase, Rental and Leasing Considerations
AutoMoverBot publishes purchase, short-term hire, monthly rental, long-term lease discussion and financing material. Its own commercial pages position ownership for stable daily long-term use and rental for temporary, seasonal or pilot requirements. Use this as a starting hypothesis. The deciding facts are the signed scope, equipment model, site responsibilities, support obligations and exit rights.
| Route | When it may fit | Contract points that need written answer |
| Purchase | High, stable use and long investment horizon. | Warranty, support, acceptance, spares, obsolescence and resale risk. |
| Short-term hire | Event, seasonal surge or proof of concept. | Delivery, training, insurance, deposit, use limits and collection. |
| Monthly rental | Flexibility while process is proven. | Term, rate, included service and termination rights. |
| Long-term lease | Spreading cost, potentially including support. | Ownership, residual, buyout, service and early termination. |
| Finance arrangement | Eligible cash-flow planning. | Total cost, credit eligibility, jurisdiction and funded scope. |
Request two comparable proposals: a time-bounded pilot with representative vehicles and pass/fail tests; and an operational proposal with complete recurring cost, support and availability assumptions. Never compare an all-in manual operation against a robot-only purchase price.
23. Robotic Parking Safety
Robotic parking is not made safe by a marketing label, sensor list or standard title. A defensible safety case combines a defined operating domain; compatible vehicles; load engagement verification; pedestrian separation; protective detection; speed control; safe stopping; energy isolation; inspected floor/environment; trained people; maintenance; and recovery. ISO 12100 sets a general methodology for machinery risk assessment and risk reduction. ISO 13849-1 provides requirements for safety-related parts of control systems. ISO 3691-4 is relevant where its driverless industrial-truck scope applies, but it does not certify every parking application or displace local machinery, building, fire, electrical, accessibility and workplace law.
| Safety layer | Practical control | Evidence required |
| Intended use | Defined vehicles, zone, speed, weather and hours. | Controlled operating-domain documentation. |
| Vehicle acceptance | Mass, geometry, tyres, clearance and condition check. | Rejection rules and compatibility evidence. |
| Engagement | Confirmed lifting/clamping/support state. | Test results for failed/partial engagement. |
| People separation | Barriers, access control, crossings and supervision. | Zone plan and human-interaction validation. |
| Detection | Protective sensing appropriate to hazards. | Fields, blind zones, diagnostics and test record. |
| Stopping | Emergency/protective stop, braking and restart rules. | Loaded stopping/restart tests. |
| Environment | Surface, water, dust, lighting, slope and drainage controls. | Survey and routine inspection evidence. |
| Charging | Dry, protected and electrically controlled space. | Battery/charger inspection and emergency plan. |
| Recovery | Formal response to stranded robot, load or power loss. | Drill, competence and escalation record. |
AutoMoverBot’s AMB page instructs trained and authorised use, designated operating positions, exclusion of body parts from moving machinery, no passenger use, capacity compliance, pre-operation inspection and no repair while powered. It also refers to electromagnetic braking. Its troubleshooting page lists emergency-button state, battery status, reset interruption, ground condition, water, dust, remote-control distance and dry charging constraints. Those official statements are useful operating inputs, not an independent safety certification or complete site plan.
24. Common Robotic Parking Failure Modes
Treat failure as a normal operating condition. First stop dispatch and secure the area. Then establish whether the vehicle is supported, whether people are protected, whether the route blocks emergency access and who is authorised to recover the system. Repeated reset attempts, bypassing safeguards and untrained intervention under a vehicle are not acceptable recovery strategies.
| Condition | Official AutoMoverBot context, where published | Immediate objective | Preventive action |
| No response | Troubleshooting advises checking emergency button and battery. | Diagnose safely before reset. | Pre-use check, charge plan and fault log. |
| E-stop active | E-stop state is mentioned. | Find cause, clear hazard and authorise restart. | Cause recording and reset control. |
| Sequence interrupted | Reset during continuous action can interrupt sequence. | Establish load/lift state first. | Training and approved recovery method. |
| Position error | Uneven ground/wrong reference may cause it. | Prevent release/next mission until verified. | Survey, calibration and change control. |
| Standing water | Do not enter over 20 mm or soak robot. | Stop, drain and inspect area. | Drainage, flood warning and weather policy. |
| High dust | Avoid continuous high dust; clean laser head. | Inspect sensing and clean safely. | Housekeeping schedule. |
| Remote range | Do not use beyond 10 m. | Remain within operating boundary. | Defined control position and radio test. |
| Network loss | Exact published loss-of-link behaviour is unavailable. | Transition to defined safe state. | Coverage, monitoring and written fallback. |
| Power loss | Public recovery procedure not identified. | Secure load/route and execute plan. | Contractual recovery and resilience design. |
| Incompatible vehicle | Full public wheel/tyre matrix unavailable. | Reject/quarantine. | Intake controls and vehicle trials. |
The supplier troubleshooting instruction that a remaining interrupted operation be manually completed must be read with the current approved manual and local risk assessment. It cannot be generalised as permission to improvise around an elevated load.
Maintenance and resilience
AutoMoverBot’s logistics content says periodic inspection of clamping mechanisms and sensors is recommended. Detailed intervals, spare-parts lead times, battery policy and service obligations should be specified in the proposal for the exact equipment.
| Asset | Routine preventative activity | Immediate withdrawal trigger |
| Clamp/lift | Inspect contact surfaces, alignment, fasteners and abnormal noise. | Incomplete/unequal engagement or visible damage. |
| Sensors/laser | Clean, inspect, function-check and calibrate as specified. | Persistent fault, contamination or blind-zone concern. |
| Wheels/drive/brakes | Check wear, debris, traction and brake function. | Abnormal vibration, loss of traction/control or brake issue. |
| Battery/charger | Check casing, cable, connector, temperature and charge record. | Swelling, leak, overheating, damaged cable or isolation fault. |
| Emergency stop | Test according to documented procedure. | Does not stop, restart is unexpected or log absent. |
| Floor/route | Check water, oil, dust, joints, obstacles and markings. | Condition outside operating limits. |
25. Vehicle Compatibility
Vehicle compatibility is a hard operating boundary, not a marketing generalisation. A vehicle-moving robot may be able to move a conventional vehicle only if its mass, wheelbase, ground clearance, wheel/tyre geometry, condition and route fit the approved envelope. The actual configuration can differ materially from brochure dimensions.For the AutoMoverBot product page headed SEMI AUTOMATIC VEHICLE MOVING (AMR), the published first-pass limits include 3.0 t maximum vehicle load, 2.05 m maximum width excluding mirrors, 5.5 m maximum length subject to a stated overhang condition, 1.3 m minimum wheelbase and 11.5 cm minimum ground clearance. The reviewed site does not publish a complete tyre, axle-load, wheel-position, steering-lock, overhang or underbody matrix. Require it in writing and validate physically.
| Factor | Why it matters | Required pre-deployment record |
| Actual mass | Lift, brake, traction and floor load. | Actual operational mass and axle-load assumptions. |
| Width/length | Gates, aisles, columns, turns and storage. | Body/mirror dimensions, accessories and overhang. |
| Wheelbase/track | Engagement geometry and stability. | Exact dimensions by vehicle class. |
| Clearance | Under-car approach and contact risk. | Lowest point along actual approach path. |
| Tyres/wheels | Contact, grip and support. | Size, condition, pressure and unusual geometry. |
| Vehicle state | Brake, steering, locks, alarms and damage. | Approved state and prohibited-condition list. |
| EV/hybrid details | Mass, underbody battery and charging interface. | Handling restrictions and disconnected-cable policy. |
| Modifications | Spoilers, skirts, tow bar or suspension changes. | Photographs and exception classification. |
Before deploying, verify the entire vehicle population, not a typical saloon. Include the heaviest, longest, lowest, shortest-wheelbase, EV, non-running and most frequently processed vehicles. Verify robot entry, engagement, route, placement, retrieval and release for each approved class.